
选择地面站
[copywiki目的地="飞机,copter,rover,blimp,sub"].
选择地面站
本页对可用的地面控制进行了高级别概述 车站(GCS 这是什么? ) 并提供链接,以便你能够做出适当的 选择。
概览
地面站一般为软件应用,运行在 通过**无线遥测**或USB电缆与 我们会与你的无人机通信的地面计算机、电话或发射机。 它显示实时数据 无人驾驶航空器的性能和位置,可充当“虚拟飞行器” 驾驶舱),显示许多与您如果 你当时正开着证明了这一点 GCS也可以用来证明了这一点,控制无人驾驶航空器。 飞行,上传新的任务命令和设置参数。 没错 也经常用来监控无人机摄像头的视频流。
还需要一个GCS在使用前设置自动驾驶器的配置,并更新自动驾驶器的固件.
至少有十个不同的地面站. 在桌面上有特派团 规划员, APM规划师2, MAVProxy 软件, 回合控制, UgCS( UgCS) 语录, and LOGOS. For Tablet/Smartphone there are QGroundControl, Tower (DroidPlanner 3), MAVPilot, AndroPilot and SidePilot that can be used to communicate with ArduPilot.
The decision to select a particular GCS often depends on your vehicle and preferred computing platform:
- Ready-to-fly users may prefer the portability and ease of use of QGroundControl, or another GCS running on a tablet or phone.
- DIY/Kit users and developers often have to access configuration and analysis tools, and would therefore need (at least initially) Mission Planner, QGroundControl, APM Planner 2 or another more full-featured GCS.
- Code Developers will appreciate some of MAVProxy's features.
Desktop GCSs
Mission Planner
Full featured and widely used GCS.
- Platform: Windows, Mac OS X (Using Mono)
- Licence: Open source (GPLv3)

- Download
- **Wiki **
- Support Forum
- Issues List
- Source Code
APM Planner 2.0
A GCS for use on macOS, Linux & Windows platforms. It has a smaller user base and a reduced feature set when compared with others.
Platform: Windows, macOS, Linux
- Licence: Open source
(GPLv3)
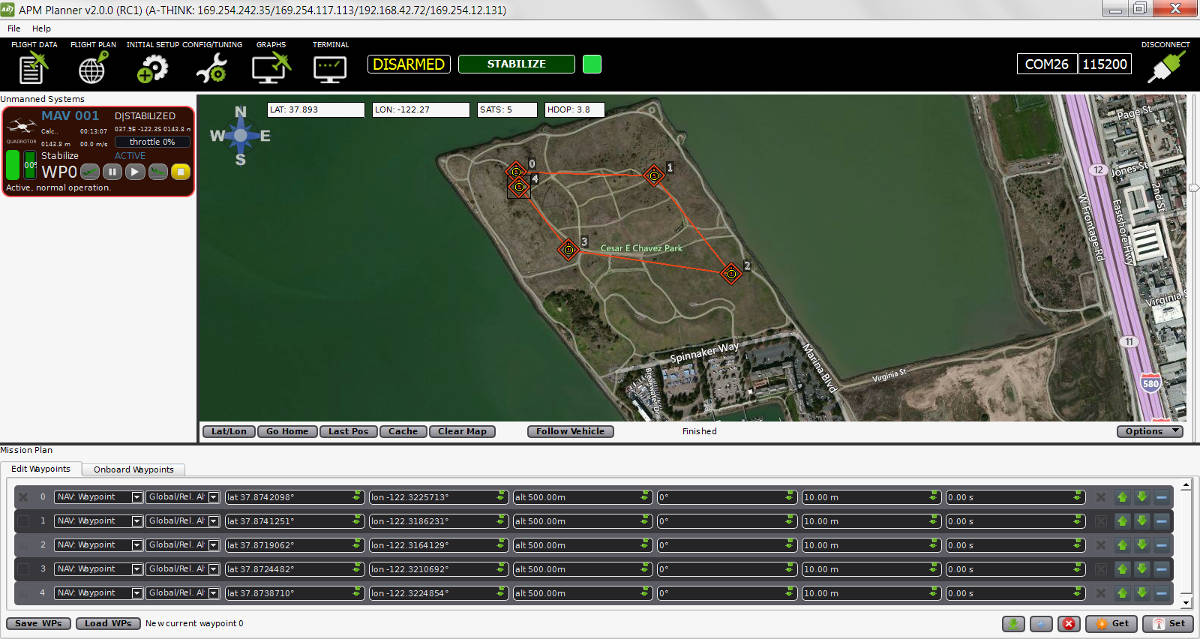
**Wiki **

MAVProxy
Linux GCS often used by code developers. Primarily a command line interface with graphical modules for map and mission editing. Written in Python, and extensible via python modules.
- Platform: Linux
- Licence: Open source (GPLv3)

- **Wiki **
- Issues List
- Source Code
QGroundControl
QGroundControl works with MAVLink capable autopilots including ArduPilot. It's unique among the GCS offerings as it runs on all platforms desktop and mobile.
- Platform: Windows, Mac OS X, Linux, Android and iOS
- Licence: Open Source (GPLv3)

UgCS - Universal Ground Control Station
Universal and easy to use ground control station with a 3D interface. Supports APM, Pixhawk as well as drones from other manufacturers such as DJI, Mikrokopter and more. Intended for enthusiasts as well as professional users.
It is capable of communicating with and controlling multiple drones simultaneously.
UgCS supports multiple map layers as well as different map providers. Some of the features of UgCS include - DEM Import, ADS-B transponder and receiver support, Click & Go mode, Joystick mode, image geotagging and video recording. UgCS also comes with a telemetry player, allowing the replay of all flights.
UgCS comes with in-built no-fly zones around all major airports as well as the ability to create custom no-fly zones.
Supports multi-node installation, meaning that it is possible to connect multiple pilots with UgCS laptops in the field to a central ground control server.
- Platform: Windows, Mac OS X, Ubuntu
- Licence: Proprietary with a free licence available as well (UgCS Open)
- UgCS Website
- DIY Drones Group for UgCS Users
- UgCS Github Repository
LOGOS
GCS designed to streamline the planning of complex missions that include area scanning, taking photos, & videos. It provides a 3D view mode, binding of physical structures and an in-built simulator that helps to better visualize planned missions.
- Platform: Windows
- Licence: Proprietary. Can be used freely, but advanced features are not available without purchase.

Mobile GCSs
QGroundControl
QGroundControl works with MAVLink capable autopilots including ArduPilot. It's unique among the GCS offerings as it runs on all platforms desktop and mobile.
- Platform: Windows, Mac OS X, Linux, Android and iOS
- Licence: Open Source (GPLv3)
Tower
Tower (a.k.a. "DroidPlanner 3") is an Android GCS for phones and tablets. It is intended for end users and enthusiasts, and includes features like follow-me, “dronies” (i.e. “selfies” but taken with a drone) and special missions for 3D mapping.
- Platform: Android Phones and Tablets
- Licence: Open source (GPLv3)

- Download Tower (and 3DR Services) from Google Play.
- Android compatible hardware list
- Wiki
- Support Forum
- Issues List
- Source Code
说明:
Legacy versions (DroidPlanner 2 and Droid Planner 1) can also be downloaded from Google Play.
MAV Pilot 1.4
A GCS in your pocket that supports predominantly ArduPilot autopilot on iPhone/iPad. Supports for Plane, Copter & Rover vehicle types
See website for how-to on how connect it to your autopilot
- Platform: iPhone, iPad
- Licence: Proprietary

SidePilot
ArduPilot compatible GCS that runs on iPhone/iPad.
See website for how-to on how connect it to your autopilot
- Platform: iPhone, iPad
- Licence: Proprietary

AndroPilot
Android GCS intended for enthusiasts.
说明:
AndroPilot is not under active development. Its suitability for newer FW needs to be confirmed.
- Platform: Android Phones and Tablets
- Licence: Open Source (GPLv3)

Additional GCS hardware
Android
For Android devices, you will need:
- Android based tablet or smartphone. QGroundControl can utilize Bluetooth, WIFI, or USB connectivity to the autopilot from the phone. For USB the device must be ablke to act as a USB host (OTG).
- A connectivity method to vehicle's autopilot:
- SiK Telemetry Radio System ** or other radio telemetry (**common-telemetry-landingpage) with OTG cable can be used for long range, in-the-air, connectivity to a similar vehicle telemetry unit.
- WIFI (common-esp8266-telemetry)
- Bluetooth (common-mission-planner-bluetooth-connectivity)
- for benchtop USB connectivity, a USB OTG cable (typically less than $2 on ebay and Amazon ).
- Some other telemetry method (common-telemetry-landingpage)
iOS
For iOS devices, you will need:
- iOS Based devices such as an iPad or iPhone. If running iPad, the cellular version is recommended for better GPS support.
- Wifi or Bluetooth LE link to the Drone
- Bridge Connection to a **SiK Telemetry Radio System ** via Wifi or Bluetooth LE
See iOS App Vendors for more details.
Desktop PCs (Windows/Mac/Linux)
For Desktop devices you will need:
- A USB cable, BT module, WIFI adapter, or other connectivity means as listed here (common-telemetry-landingpage)
[site wiki="plane"]
[/site] [site wiki="copter"]
[/site] [site wiki="rover"]
[/site] [site wiki="sub"]
[/site]
【本页后半部分仍为英文原文摘录,补译中。】
译自 ArduPilot Copter「[copywiki destination="plane,copter,rover,blimp,sub"]」· 查看原文 · CC BY-SA 3.0
没有要显示的评论
没有要显示的评论