
设置电机行程
大多数ESC在它们的射程底部有一个死区. 本页概述了如何测试射程的大小,然后适当设置自旋-当臂和节流阀值.
虽然不需要,但高级用户不妨采取下一步措施,测量和调整**机动车推力曲线**。
说明
请在设定运动范围前完成**ESC校准**
测量死区
把螺旋桨从车上取出来
连接 LiPo 电池
使用USB电缆或遥测技术将自动驾驶机连接到飞行任务规划员
打开任务规划员的初始设置 可选硬件QQ 汽车测试页面
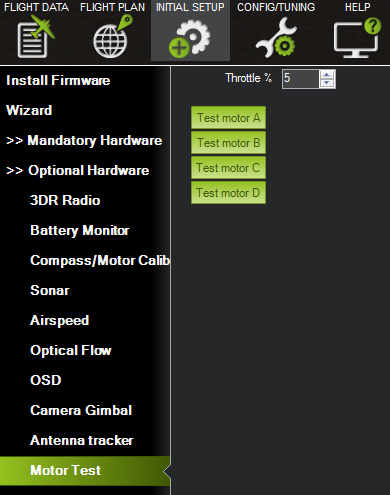
增加"Throttle %"字段,并按下每个"Test motor"按钮,以确定每个马达旋转所需的百分比. 如果所有ESC都来自同一制造商,那么它们都可能有类似的死区,但有1%~2%的一两个不同的是常见的. 在所有马达中选择最高比例——下面使用这个.

设置自旋和微调
默认情况下,当机体配备了武器但没有飞行时,发动机的旋转速度会略慢于正常速度. 此速度可以使用ء子岛ءيش 汝 . 一旦机器飞起来,我们想确保我们永远不输出一个导致机器停止转动的数值,这个下限可以被组合成**MOT SPIN MIN parameter.
- set the MOT_SPIN_ARM ** parameter to **(the percentage discovered above + 2%) / 100. I.e. if you found the deadzone of the ESCs was 7%, set **MOT_SPIN_ARM ** to 0.09 (i.e (7 + 2) / 100).
- set the **MOT_SPIN_MIN ** parameter to at least 0.03 higher than **MOT_SPIN_ARM **. I.e. if **MOT_SPIN_ARM ** was 0.09, set **MOT_SPIN_MIN ** to 0.12.
说明
Setting **MOT_SPIN_MIN ** even higher than recommended above is acceptable if we want to account for voltage drop of the battery, but setting it too high reduces the lower range of the motors which reduces control which could be important, especially on powerful copters with a low hover throttle.
说明
The **MOT_SPIN_MAX ** parameter to account for the very top of the ESC/motor range which generally produces no additional thrust. By default this value is 0.95 (i.e. top 5% of the range produces no additional thrust).
说明
if ESC RPM telemetry is being used, the TKOFF_RPM_MIN parameter could be set slightly below the **MOT_SPIN_ARM ** parameter to prevent takeoff attempts, and subsequent flips on takeoff, if one or more motors are not spinning.
IDLE State Time
If needed, you can add delay between the time the motor idle state is reached and when increased throttle can be applied to the ESCs using the **MOT_IDLE_SEC ** parameter (default is 0 seconds).
【本页后半部分仍为英文原文摘录,补译中。】
译自 ArduPilot Copter「Setting Motor Range」· 查看原文 · CC BY-SA 3.0