
HeliQuad
宽度 : 100%
ArduPilot支持HeliQuads,也称集体皮奇四面体或可变皮奇多面体.
这些机体在4个旋转器上每个旋转器上都使用独立控制的集体抛管,单电动机通过带和扭矩管以同样的速度将 Sugare 4个 Ferrari的旋转器全部电动. 它具有高度的有氧性,能够反转飞行,但可受到**高振动水平**。
连接和配置

- 每个伺服器出版物应使用普通多复制机上用于发动机的相同输出进行连接(**,请参见这里的顺序**)
- the motor's ESC should be connected to the autopilot's channel 8 output
- **traditional helicopter firmware ** should be loaded onto the vehicle.
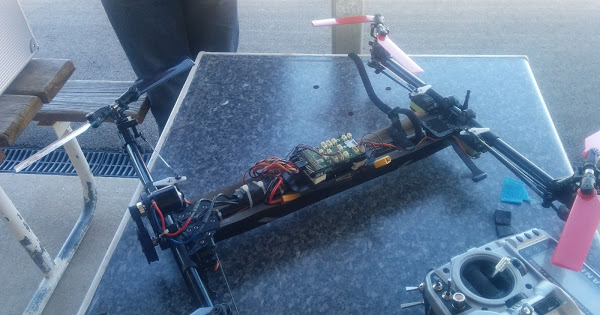
If using the WLToys Assassin V383 a parameter file is available here and can be used to set all parameters immediately. For other builds these are the standard params that should be set:
- **FRAME_CLASS ** to 13 (HeliQuad)
- **FRAME_TYPE ** to 1 ("X" if front right motors spins counter clockwise) or 3 ("H" if front right motor spins clockwise)
Similar to a traditional helicopter ** an **auxiliary switch ** should be set to "Motor Interlock" to turn on/off the motor. Normally this is channel 8 so you could set **RC8_OPTION to 32.
【本页后半部分仍为英文原文摘录,补译中。】
译自 ArduPilot Copter「HeliQuads (Variable Pitch Multicopters)」· 查看原文 · CC BY-SA 3.0