# 双直升机
**说明**:
Dual Heli Frame需要\*\*传统直升机\*\*作为基地固件. 该手册可从秘书处下载。[固件服务器](https://firmware.ardupilot.org/)当为固件服务器生成Copter时,它同时生成多旋转器和传统的直升机(向受害者提供-heli后缀)固件.
## 连接和配置
- 发动机的ESC应连接到自动驾驶8频道输出
- \*\* 传统的直升机固件在委员会上应装上。
- \*\*FRAME CLASS \*\*至11(赫尔辛基)
- \*\*H DUAL MODE \*\*
类似**传统直升机 \*\* 一个\*\*辅助开关 \*\* 应设置为"Motor Interlock"以开启/关闭发动机. 通常这里是8频道,所以可以设置\*\*RC8 OPTION**改为32。
**说明**:
见**traditional-helicopter-swashplate-setup** for basic information on how to setup each swashplate using the parameters below.
## Tandem (Longitudinal)
[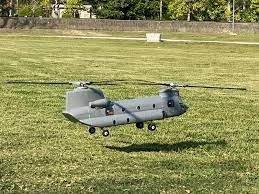](https://doc.yufeiaero.com/_images/dual_heli_chinook.jpeg)This setup assumes that the forward rotor swashplate is controlled by servo output 1, 2, and 3 and the aft rotor swashplate is controlled by servo output 4, 5 and 6.
Parameter Settings:
- **H\_DUAL\_MODE** - Set to 0 for the longitudinal configuration
- **H\_DCP\_SCALER** - Scales the differential collective output to the rotors for a pitch axis input
- **H\_DCP\_YAW** - Feedforward input to yaw axis for pitch axis (DCP) inputs
- **H\_YAW\_SCALER** - Scales the differential lateral cyclic based on yaw axis input. This is a positive number for this setup.
- **H\_COL\_MAX**- PWM for maximum collective pitch on forward rotor head that corresponds to **H\_COL\_ANG\_MAX**
- **H\_COL\_MIN** - PWM for minimum collective pitch on forward rotor head that corresponds to **H\_COL\_ANG\_MIN**
- **H\_SW\_TYPE** - Swashplate type for forward rotor head
- **H\_SW\_COL\_DIR** - Swashplate collective direction for forward rotor head
- **H\_SW\_LIN\_SVO** - Enables linear servo feature for forward rotor head
- **H\_COL2\_MIN** - PWM for minimum collective pitch on aft rotor head that corresponds to **H\_COL\_ANG\_MIN**
- **H\_COL2\_MAX**- PWM for maximum collective pitch on aft rotor head that corresponds to **H\_COL\_ANG\_MAX**
- **H\_SW2\_TYPE** - Swashplate type for aft rotor head
- **H\_SW2\_COL\_DIR** - Swashplate collective direction for aft rotor head
- **H\_SW2\_LIN\_SVO** - Enables linear servo feature for aft rotor head
- **H\_DCP\_TRIM** - Removes pitch I term bias due to center of gravity offsets or discrepancies between rotors in swashplate setup. If pitch axis has I term bias while hovering in calm winds, use value of bias in DCP\_TRIM to re-center I term.
These are only needed for the forward swashplate if **H\_SW\_TYPE** is set to H3 Generic.
- **H\_SW\_H3\_ENABLE** - Do Not Set Manually! This is set automatically once **H\_SW\_TYPE** is set to H3 Generic
- **H\_SW\_H3\_SV1\_POS**
- **H\_SW\_H3\_SV2\_POS**
- **H\_SW\_H3\_SV3\_POS**
- `H_SW_H3_PHANG`
These are only needed for the aft swashplate if **H\_SW2\_TYPE** is set to H3 Generic.
- **H\_SW2\_H3\_ENABLE** - Do Not Set Manually! This is set automatically once **H\_SW2\_TYPE** is set to H3 Generic
- **H\_SW2\_H3\_SV1\_POS**
- **H\_SW2\_H3\_SV2\_POS**
- **H\_SW2\_H3\_SV3\_POS**
- `H_SW2_H3_PHANG`
This parameter is not used for the longitudinal configuration - **H\_YAW\_REV\_EXPO**
## Side-by-Side (Transverse)
[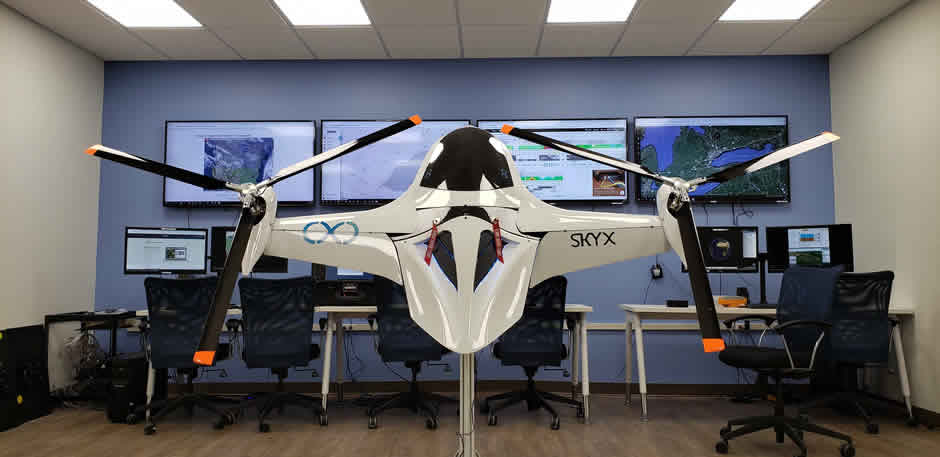](https://doc.yufeiaero.com/_images/dual_heli_transverse.jpg)This setup assumes that the left rotor swashplate is controlled by servo output 1, 2, and 3 and the right rotor swashplate is controlled by servo output 4, 5 and 6.
Parameter Settings:
- **H\_DUAL\_MODE** - Set to 1 for the transverse configuration
- **H\_DCP\_SCALER** - Scales the differential collective output to the rotors for a roll axis input
- **H\_DCP\_YAW** - Feedforward input to yaw axis for roll axis (DCP) inputs
- **H\_YAW\_SCALER** - Scales the differential longitudinal cyclic based on yaw axis input. This is a positive number for this setup.
- **H\_COL\_MAX**- PWM for maximum collective pitch on left rotor head that corresponds to **H\_COL\_ANG\_MAX**
- **H\_COL\_MIN** - PWM for minimum collective pitch on left rotor head that corresponds to **H\_COL\_ANG\_MIN**
- **H\_SW\_TYPE** - Swashplate type for left rotor head
- **H\_SW\_COL\_DIR** - Swashplate collective direction for left rotor head
- **H\_SW\_LIN\_SVO** - Enables linear servo feature for left rotor head
- **H\_COL2\_MIN** - PWM for minimum collective pitch on right rotor head that corresponds to **H\_COL\_ANG\_MIN**
- **H\_COL2\_MAX**- PWM for maximum collective pitch on right rotor head that corresponds to **H\_COL\_ANG\_MAX**
- **H\_SW2\_TYPE** - Swashplate type for right rotor head
- **H\_SW2\_COL\_DIR** - Swashplate collective direction for right rotor head
- **H\_SW2\_LIN\_SVO** - Enables linear servo feature for right rotor head
- **H\_DCP\_TRIM** - Removes roll I term bias due to center of gravity offsets or discrepancies between rotors in swashplate setup. If roll axis has I term bias while hovering in calm winds, use value of bias in DCP\_TRIM to re-center I term.
These are only needed for the left swashplate if **H\_SW\_TYPE** is set to H3 Generic.
- **H\_SW\_H3\_ENABLE** - Do Not Set Manually! This is set automatically once **H\_SW\_TYPE** is set to H3 Generic
- **H\_SW\_H3\_SV1\_POS**
- **H\_SW\_H3\_SV2\_POS**
- **H\_SW\_H3\_SV3\_POS**
- `H_SW_H3_PHANG`
These are only needed for the right swashplate if **H\_SW2\_TYPE** is set to H3 Generic.
- **H\_SW2\_H3\_ENABLE** - Do Not Set Manually! This is set automatically once **H\_SW2\_TYPE** is set to H3 Generic
- **H\_SW2\_H3\_SV1\_POS**
- **H\_SW2\_H3\_SV2\_POS**
- **H\_SW2\_H3\_SV3\_POS**
- `H_SW2_H3_PHANG`
This parameter is not used for the longitudinal configuration
- **H\_YAW\_REV\_EXPO**
## Intermeshing
[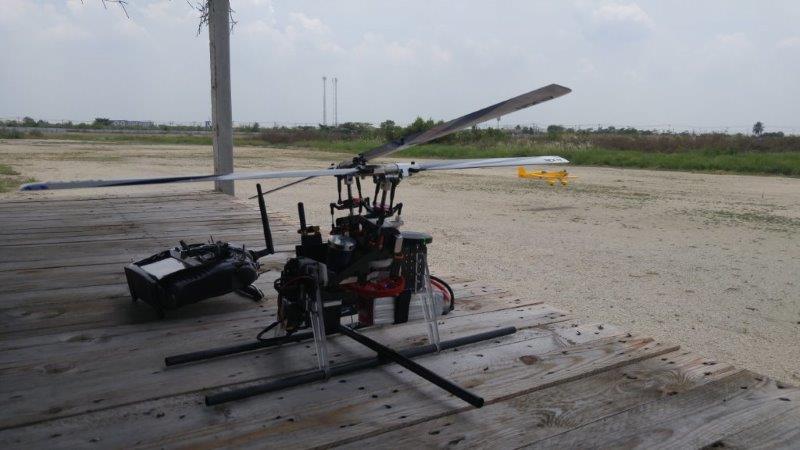](https://doc.yufeiaero.com/_images/dual_heli_intermeshing.jpg)This setup assumes that the left rotor swashplate is controlled by servo output 1, 2, and 3 and the right rotor swashplate is controlled by servo output 4, 5 and 6.
Parameter Settings:
- **H\_DUAL\_MODE** - Set to 2 for the intermeshing configuration
- **H\_DCP\_SCALER** - Scales the differential collective output to the rotors for a yaw axis input. For a positive value the left rotor would spin counter clockwise to give the proper yaw response.
- **H\_YAW\_SCALER** - Scales the differential longitudinal cyclic based on yaw axis input. This is a positive number for this setup.
- **H\_COL\_MAX**- PWM for maximum collective pitch on left rotor head that corresponds to **H\_COL\_ANG\_MAX**
- **H\_COL\_MIN** - PWM for minimum collective pitch on left rotor head that corresponds to **H\_COL\_ANG\_MIN**
- **H\_SW\_TYPE** - Swashplate type for left rotor head
- **H\_SW\_COL\_DIR** - Swashplate collective direction for left rotor head
- **H\_SW\_LIN\_SVO** - Enables linear servo feature for left rotor head
- **H\_COL2\_MIN** - PWM for minimum collective pitch on right rotor head that corresponds to **H\_COL\_ANG\_MIN**
- **H\_COL2\_MAX**- PWM for maximum collective pitch on right rotor head that corresponds to **H\_COL\_ANG\_MAX**
- **H\_SW2\_TYPE** - Swashplate type for right rotor head
- **H\_SW2\_COL\_DIR** - Swashplate collective direction for right rotor head
- **H\_SW2\_LIN\_SVO** - Enables linear servo feature for right rotor head
- **H\_YAW\_REV\_EXPO** - Yaw revereser smoothing exponent, smoothen transition near zero collective region. Increase this parameter to shink smoothing range. Set to -1 to disable reverser.
These are only needed for the left swashplate if **H\_SW\_TYPE** is set to H3 Generic.
- **H\_SW\_H3\_ENABLE** - Do Not Set Manually! This is set automatically once **H\_SW\_TYPE** is set to H3 Generic
- **H\_SW\_H3\_SV1\_POS**
- **H\_SW\_H3\_SV2\_POS**
- **H\_SW\_H3\_SV3\_POS**
- `H_SW_H3_PHANG`
These are only needed for the right swashplate if **H\_SW2\_TYPE** is set to H3 Generic.
- **H\_SW2\_H3\_ENABLE** - Do Not Set Manually! This is set automatically once **H\_SW2\_TYPE** is set to H3 Generic
- **H\_SW2\_H3\_SV1\_POS**
- **H\_SW2\_H3\_SV2\_POS**
- **H\_SW2\_H3\_SV3\_POS**
- `H_SW2_H3_PHANG`
These parameters are not used for the intermeshing configuration
- **H\_DCP\_YAW**
- **H\_DCP\_TRIM**
## Coaxial
[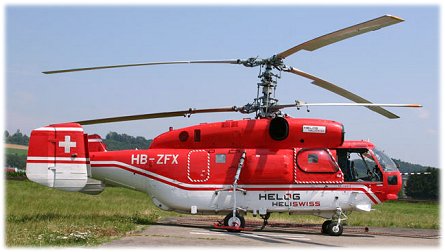](https://doc.yufeiaero.com/_images/dual_heli_coaxial.jpg)This setup assumes that the counter clockwise rotor swashplate is controlled by servo output 1, 2, and 3 and the clockwise rotor swashplate is controlled by servo output 4, 5 and 6.
Parameter Settings:
- **H\_DUAL\_MODE** - Set to 2 for the intermeshing configuration
- **H\_DCP\_SCALER** - Scales the differential collective output to the rotors for a yaw axis input.
- **H\_YAW\_SCALER** - This parameter is set to zero for the coaxial configuration.
- **H\_COL\_MAX**- PWM for maximum collective pitch on counter clockwise rotor head that corresponds to **H\_COL\_ANG\_MAX**
- **H\_COL\_MIN** - PWM for minimum collective pitch on counter clockwise rotor head that corresponds to **H\_COL\_ANG\_MIN**
- **H\_SW\_TYPE** - Swashplate type for counter clockwise rotor head
- **H\_SW\_COL\_DIR** - Swashplate collective direction for counter clockwise rotor head
- **H\_SW\_LIN\_SVO** - Enables linear servo feature for counter clockwise rotor head
- **H\_COL2\_MIN** - PWM for minimum collective pitch on clockwise rotor head that corresponds to **H\_COL\_ANG\_MIN**
- **H\_COL2\_MAX**- PWM for maximum collective pitch on clockwise rotor head that corresponds to **H\_COL\_ANG\_MAX**
- **H\_SW2\_TYPE** - Swashplate type for clockwise rotor head
- **H\_SW2\_COL\_DIR** - Swashplate collective direction for clockwise rotor head
- **H\_SW2\_LIN\_SVO** - Enables linear servo feature for clockwise rotor head
- **H\_YAW\_REV\_EXPO** - Yaw revereser smoothing exponent, smoothen transition near zero collective region. Increase this parameter to shink smoothing range. Set to -1 to disable reverser.
These are only needed for the counter clockwise swashplate if **H\_SW\_TYPE** is set to H3 Generic.
- **H\_SW\_H3\_ENABLE** - Do Not Set Manually! This is set automatically once **H\_SW\_TYPE** is set to H3 Generic
- **H\_SW\_H3\_SV1\_POS**
- **H\_SW\_H3\_SV2\_POS**
- **H\_SW\_H3\_SV3\_POS**
- `H_SW_H3_PHANG`
These are only needed for the clockwise swashplate if **H\_SW2\_TYPE** is set to H3 Generic.
- **H\_SW2\_H3\_ENABLE** - Do Not Set Manually! This is set automatically once **H\_SW2\_TYPE** is set to H3 Generic
- **H\_SW2\_H3\_SV1\_POS**
- **H\_SW2\_H3\_SV2\_POS**
- **H\_SW2\_H3\_SV3\_POS**
- `H_SW2_H3_PHANG`
These parameters are not used for the coaxial configuration
- **H\_DCP\_YAW**
- **H\_DCP\_TRIM**
*【本页后半部分仍为英文原文摘录,补译中。】*
---
*译自 ArduPilot Copter「Dual Helicopter」· [查看原文](https://ardupilot.org/copter/docs/dual-helicopter.html) · CC BY-SA 3.0*